The Bitter Lesson and How We Represent Actions
Letting the model find the answer does not make the way we write the question irrelevant.
Read the essayRobotics · Learning
Ph.D. student at KTH Royal Institute of Technology
Hello! I’m Yufei, a WASP-affiliated Ph.D. student in Division of Robotics, Perception and Learning at KTH Royal Institute of Technology supervised by Prof. Danica Kragic. My research explores how the structure of robot actions can be used to improve policies, making them more efficient, responsive, and able to generalize across diverse tasks and embodiments, combining insights from optimization and control with modern robot foundation models.
Prior to KTH, I obtained my Master degree at ETH Zurich and Bachelor degree with First Class Honours at the Hong Kong Polytechnic University. During my master’s study, I worked on path planning for fixed-wing UAVs at Autonomous Systems Lab led by Prof. Roland Siegwart and whole-body motion planning for center-articulated robot at Robotics Systems Lab led by Prof. Marco Hutter.
Feel free to reach out if you’re interested in my work or would like to collaborate!
From the lab & beyond
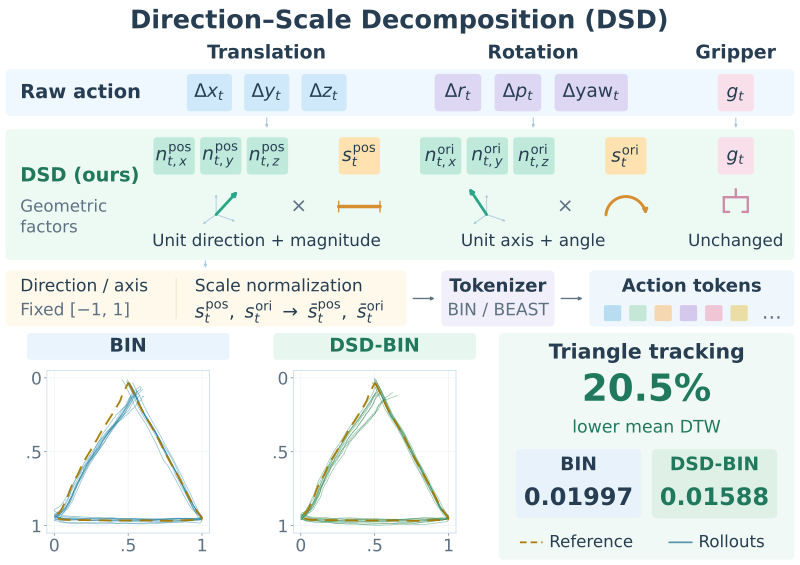
| Sep 24, 2026 | Our paper on Direction-Scale Decomposition (DSD) for vision-language-action models is available on arXiv. See the project page for demonstrations and more details. |
|---|---|
| Jul 30, 2025 | I am delighted to share that our work, Real-Time Iteration Scheme for Diffusion Policy has been accepted to IROS, Hangzhou. |
| Oct 16, 2024 | I am delighted to present our work, Energy-Optimized Planning in Non-Uniform Wind Fields with Fixed-Wing Aerial Vehicles at IROS, Abu Dhabi. |
| Feb 15, 2024 | I started my PhD study at KTH Royal Institute of Technology supervised by Prof. Danica Kragic |
| Oct 31, 2023 | I finished my master’s study at ETH Zurich. |
Ideas & reflections
Letting the model find the answer does not make the way we write the question irrelevant.
Read the essayResearch